Mariia Gladkova
PhD Candidate, Technical University of Munich · Intern, Qualcomm AI Research
I am a PhD candidate at the Technical University of Munich (Chair for Computer Vision & Artificial Intelligence), advised by Prof. Daniel Cremers, and currently interning at Qualcomm AI Research in Amsterdam. My research spans visual SLAM and 3D reconstruction, spatial AI, and open-vocabulary 3D scene understanding. Before doing PhD, I completed Master's in Informatics at TUM (2017–2021), with my thesis on direct visual odometry with relocalization published at ICRA 2021, and Bachelor's in Computer Science at Constructor University (formerly Jacobs University Bremen, 2014–2017).
I am looking for full-time opportunities starting Summer 2027 — if you think I'd be a good fit for your team, please reach out!
- mariia.gladkova [at] tum.de
News
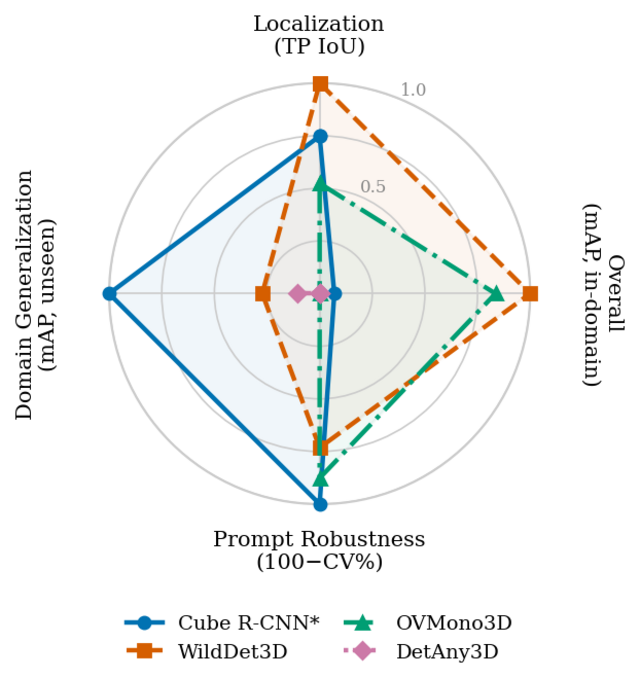
- Aug 2026 Our paper on an open-vocabulary diagnostic benchmark, OV3D-Bench, is accepted to the ECCV 2026 workshop OpenSUN3D.
- Jul 2026 Our paper on sparse-view reconstruction with geometric priors, Visdom, is accepted to GCPR 2026 as an Oral.
- Jun 2026 Started my internship at Qualcomm AI Research, working in the Generative AI, Autonomous Driving team.
Research
01
Visual SLAM & Place Recognition
Direct visual odometry with feature-based relocalization and cross-modal image–LiDAR place recognition for robust, large-scale localization.
02
3D Reconstruction, Tracking & Spatial AI
Multi-object tracking, sparse-view novel view synthesis, 4D scene understanding, and diagnostic benchmarking of open-vocabulary 3D detectors.
Selected Publications
For the full list, see my Google Scholar profile.
VisDom: Sparse Novel View Synthesis with Visible Domain Constraint
GCPR, 2026 (Oral)
Synthesizes novel views from sparse input images by constraining rendering to the visible domain, improving reconstruction quality when only a few views are available.
Project Page · arXiv · Code
TRASE: Tracking-free 4D Segmentation and Editing
3DV, 2026
Segments and edits dynamic 4D Gaussian-splatting scenes directly, without needing per-object tracking across frames.
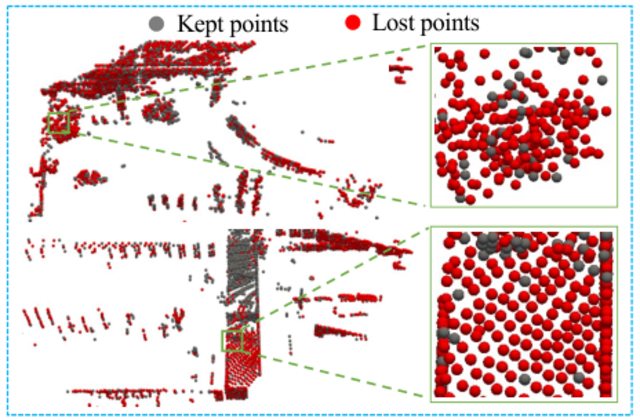
VXP: Voxel-Cross-Pixel Large-scale Image-LiDAR Place Recognition
3DV, 2025
Matches LiDAR point clouds and camera images at the voxel/pixel level for cross-modal place recognition at city scale.
Project Page · arXiv · Code
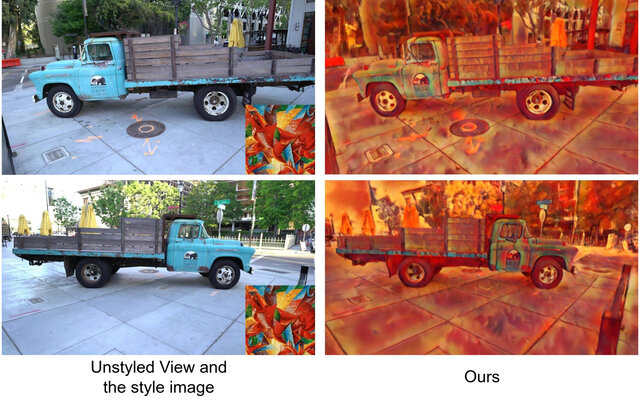
Gaussian Splatting in Style
GCPR, 2024
Stylizes 3D Gaussian-splatting scenes in real time, generalizing to new style images without retraining per scene.
DirectTracker: 3D Multi-Object Tracking Using Direct Image Alignment and Photometric Bundle Adjustment
IROS, 2022
Combines direct image alignment with sliding-window photometric bundle adjustment for accurate 3D multi-object tracking from monocular video.
Tight Integration of Feature-based Relocalization in Monocular Direct Visual Odometry
ICRA, 2021
Integrates feature-based map relocalization into direct visual odometry at the camera tracking, bundle-adjustment, and pose-fusion stages for globally accurate camera poses.
Experience
-
2026–present
Intern, Qualcomm AI Research, working with Jens Petersen and Amir Habibian
-
2021–2026
PhD Candidate, Technical University of Munich (Chair for Computer Vision & Artificial Intelligence), advised by Prof. Daniel Cremers
-
2017–2021
M.Sc. Informatics, Technical University of Munich
-
2014–2017
B.Sc. Computer Science, Constructor University (formerly Jacobs University Bremen)
Teaching & Service
- Master Seminar "Recent Advances in 4D Computer Vision", co-instructor with Cecilia Curreli — TUM, Winter 2024, Summer 2025, Winter 2025
- Master Seminar "HuMANS: 3D Human Motion Analysis", co-instructor with Cecilia Curreli — TUM, Summer 2024
- Practical Course "Learning For Self-Driving Cars and Intelligent Systems", co-instructor with Qadeer Khan — TUM, Winter 2021, Summer 2022, Winter 2022, Summer 2023
- Reviewer — CVPR, ICCV, 3DV, NeurIPS, BMVC, GCPR, WACV, ICRA, IROS, T-PAMI, RA-L, T-RO